
3D vision8 min read
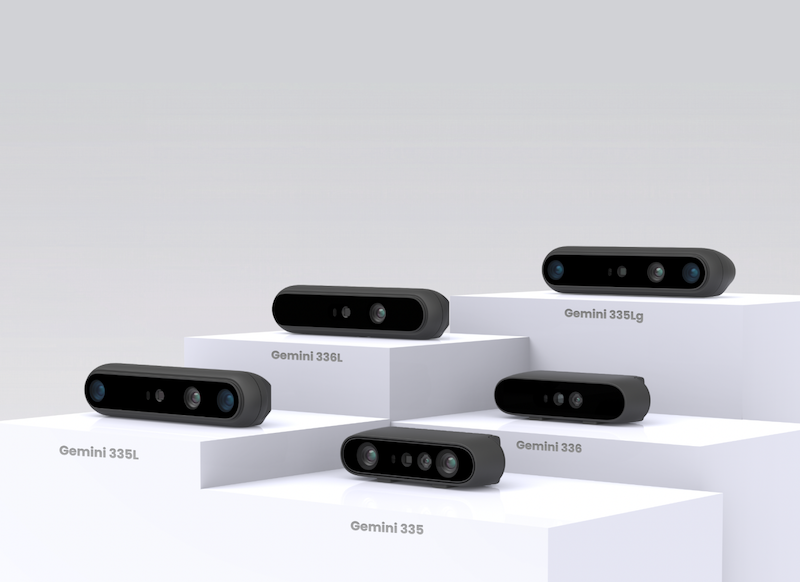
Orbbec Gemini 330 series: Active stereo cameras built on proprietary MX6800 ASIC depth processing
Engineers evaluating active stereo cameras usually compare baseline, accuracy at range, and field of view first. Where the depth map gets computed tends to come later, often after the host computer has already been specified. That order is backwards for many robotics and automation builds.


By Sam FrancisRobotics & Automation News
Read the full story
Originally published by Robotics & Automation News on Oct 26, 2026.
Comments
Sign in to join the discussion.